How does the FM-800 navigate and avoid obstacles?
It uses LiDAR-SLAM navigation with dual LiDAR sensors and camera-based obstacle avoidance, combining localization, obstacle avoidance and navigation in the base.
 FetchingRobot
中文
FM SERIES / MOBILE ROBOT BASE
The FetchingRobot FM-800 is an OEM-sourced mobile robot base for robotics development and system integration. It combines LiDAR-SLAM navigation, obstacle avoidance and automatic charging with power, USB and network connections for payload equipment and custom development.
View Specifications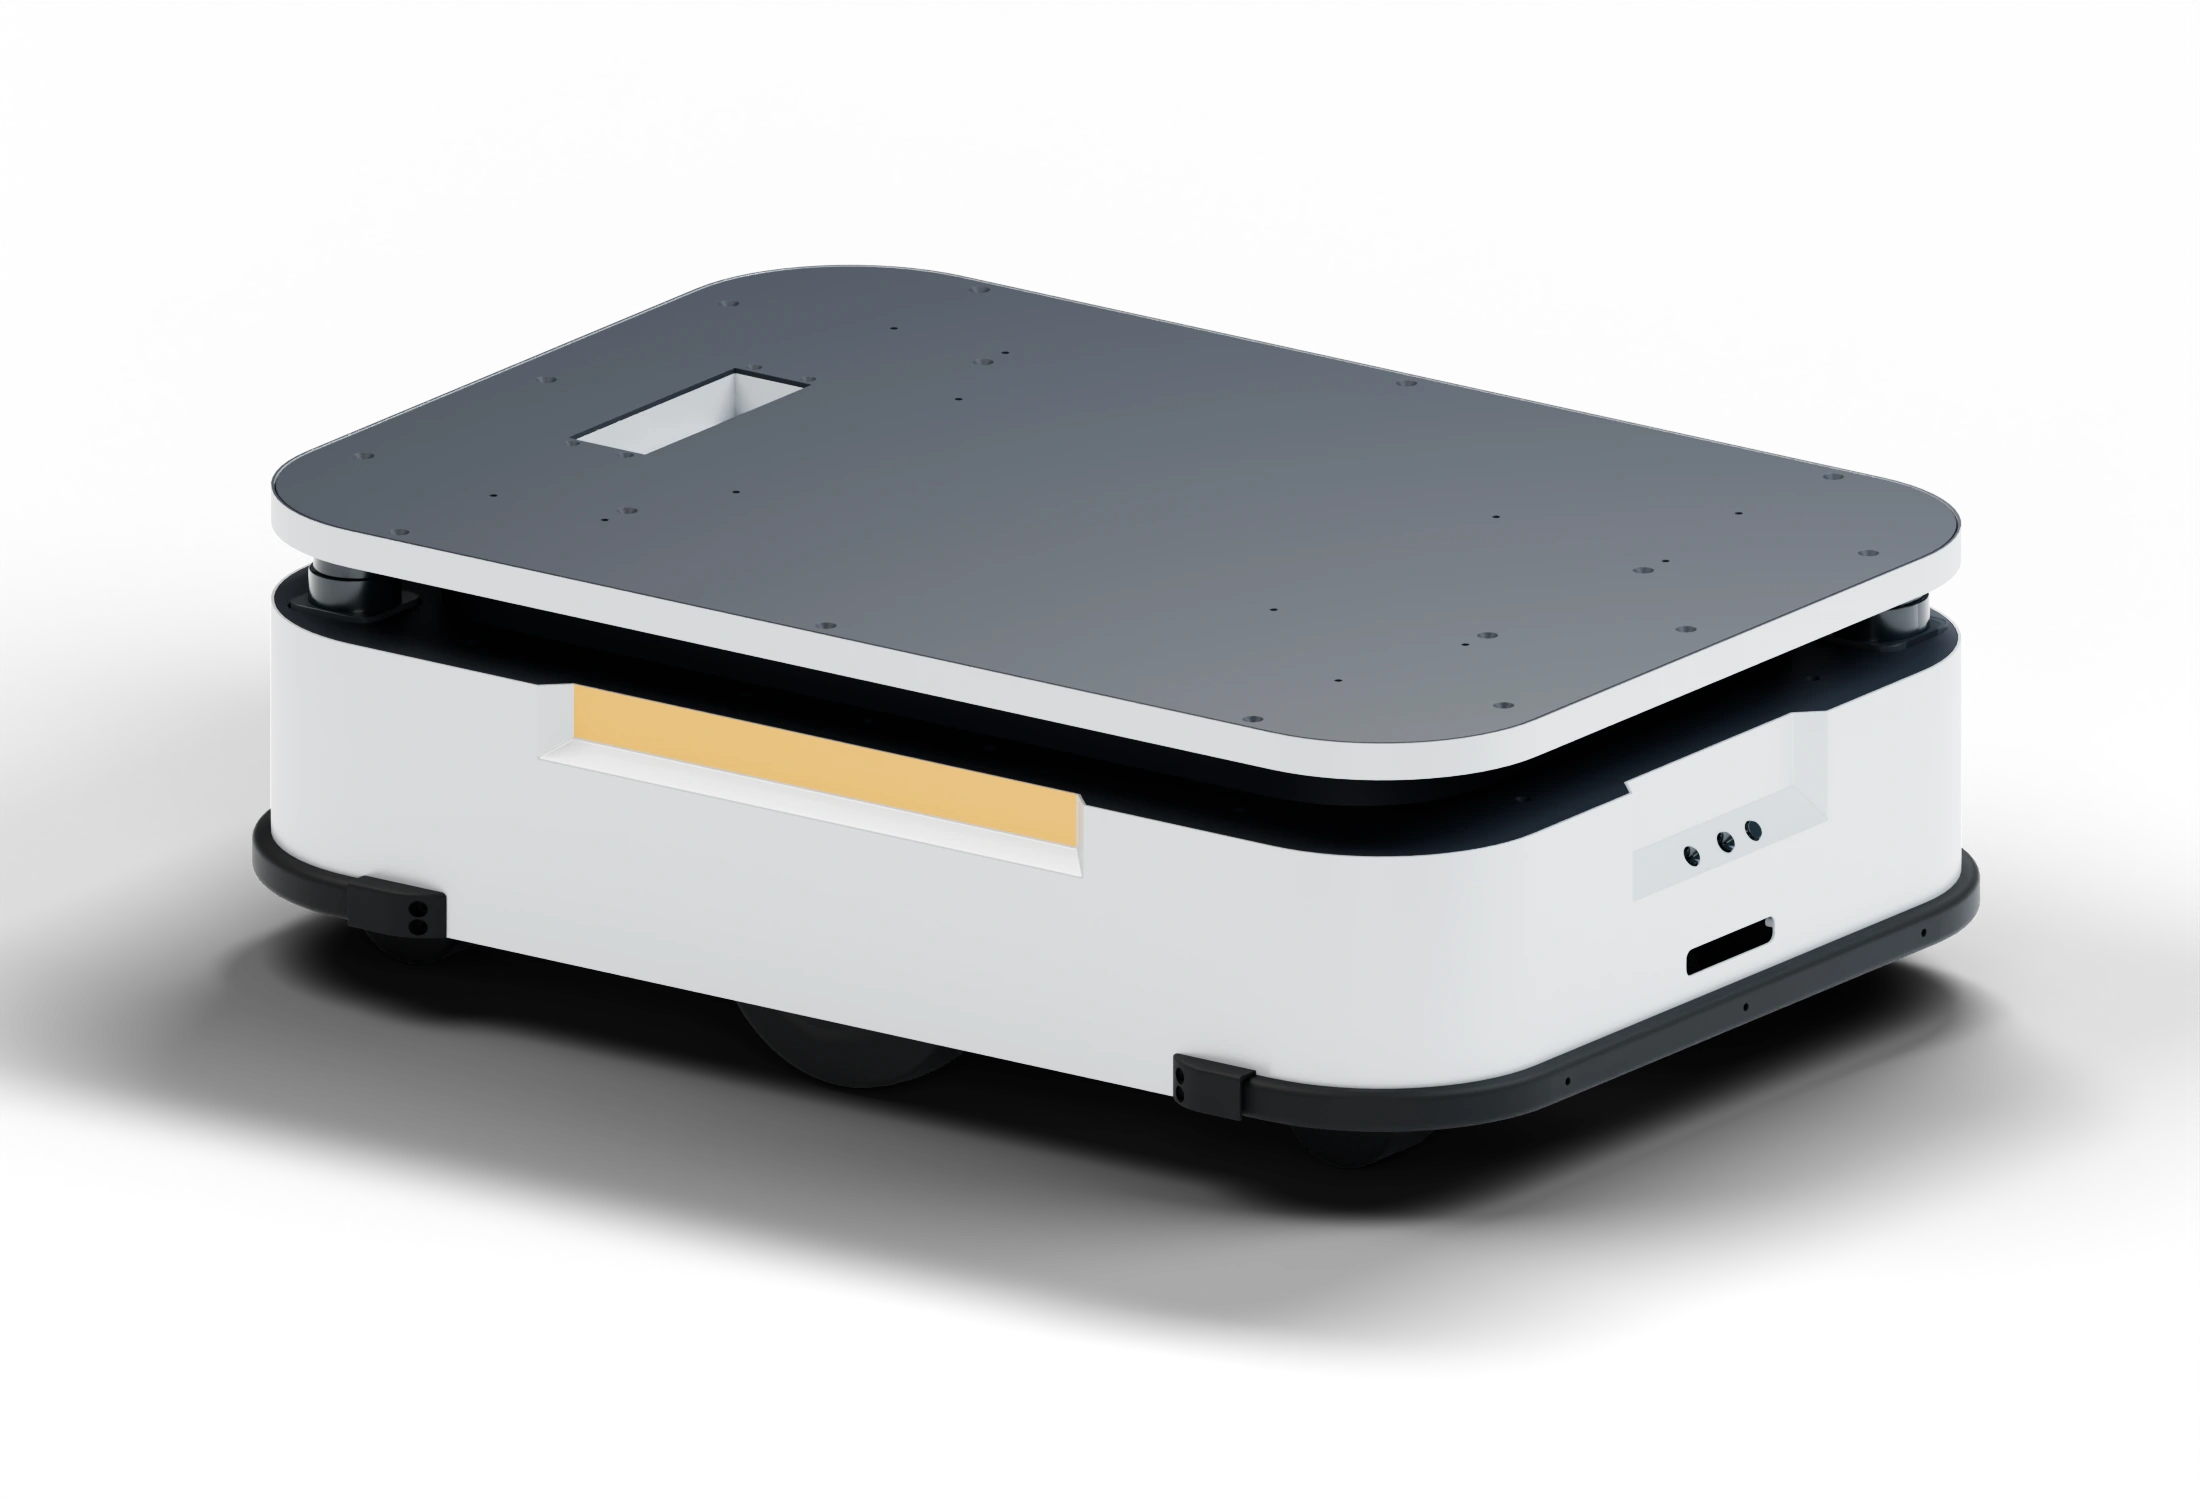
The FM-800 combines LiDAR-SLAM navigation with dual LiDAR sensors and camera-based obstacle avoidance. It carries a maximum payload of 150 kg and travels at up to 0.8 m/s.
The base provides the mobile platform for the robot’s task equipment. Payload hardware and application software can be developed around it to create a robot for a specific application.
A 30 Ah battery provides a specified runtime of 15 h under unloaded conditions. The base supports automatic charging at a charging station, reaching approximately 90% in 3 h and a full charge in 3.5 h.
Actual runtime depends on payload weight, equipment power consumption and operating conditions. The 15 h specification applies to unloaded operation.
Power, USB and network connections serve distinct roles: supplying payload equipment, connecting peripherals and exchanging data with external systems. The FM-800 supports payload integration and custom development around these interfaces.
| Interface | Specification & Function |
|---|---|
| Power output | 24 V / 30 A for compatible payload equipment. |
| USB | Two USB 2.0 ports for compatible peripherals. |
| Network | TCP/IP support for communication between the platform and external systems. |
The FM-800 measures 800 × 550 × 260 mm and weighs 65 kg. Dark and light finishes are available, along with custom colors.
Specified obstacle-crossing height is 10 mm and gap-crossing width is 40 mm. The operating temperature range is −10 °C to 45 °C. Floor conditions, load distribution and payload configuration affect performance in use.
| Overall Dimensions | 800 × 550 × 260 mm | Base Weight | 65 kg |
|---|---|---|---|
| Max. Payload | 150 kg | Battery Capacity | 30 Ah |
| Runtime | 15 h (unloaded) | Max. Travel Speed | 0.8 m/s |
| Navigation | LiDAR-SLAM | Charging Time | Approx. 3 h to 90%; approx. 3.5 h to full charge |
| Obstacle Crossing Height | 10 mm | Gap Crossing Width | 40 mm |
| Operating Temperature | −10 °C to 45 °C | Power Output | 24 V / 30 A |
| USB Ports | 2 × USB 2.0 | Network Interface | TCP/IP Support |
| Color Options | Dark / light; custom colors available | ||
Reference specifications are based on OEM platform documentation. The 15 h runtime is for unloaded operation; actual performance varies with payload, payload power demand and operating conditions. Specifications and appearance may vary by configuration.
It uses LiDAR-SLAM navigation with dual LiDAR sensors and camera-based obstacle avoidance, combining localization, obstacle avoidance and navigation in the base.
The base provides 24 V / 30 A power output, two USB 2.0 ports and a network port with TCP/IP support. It supports payload integration, peripheral connections and custom development.
The 15 h figure applies to unloaded operation. With equipment installed, runtime varies with payload weight, power consumption and operating conditions.
The base supports automatic charging at a charging station. Charging takes approximately 3 h to reach 90% and 3.5 h to reach full charge.
Dark and light finishes are available, and custom colors are supported.