FetchingRobotFetchingRobot 中文
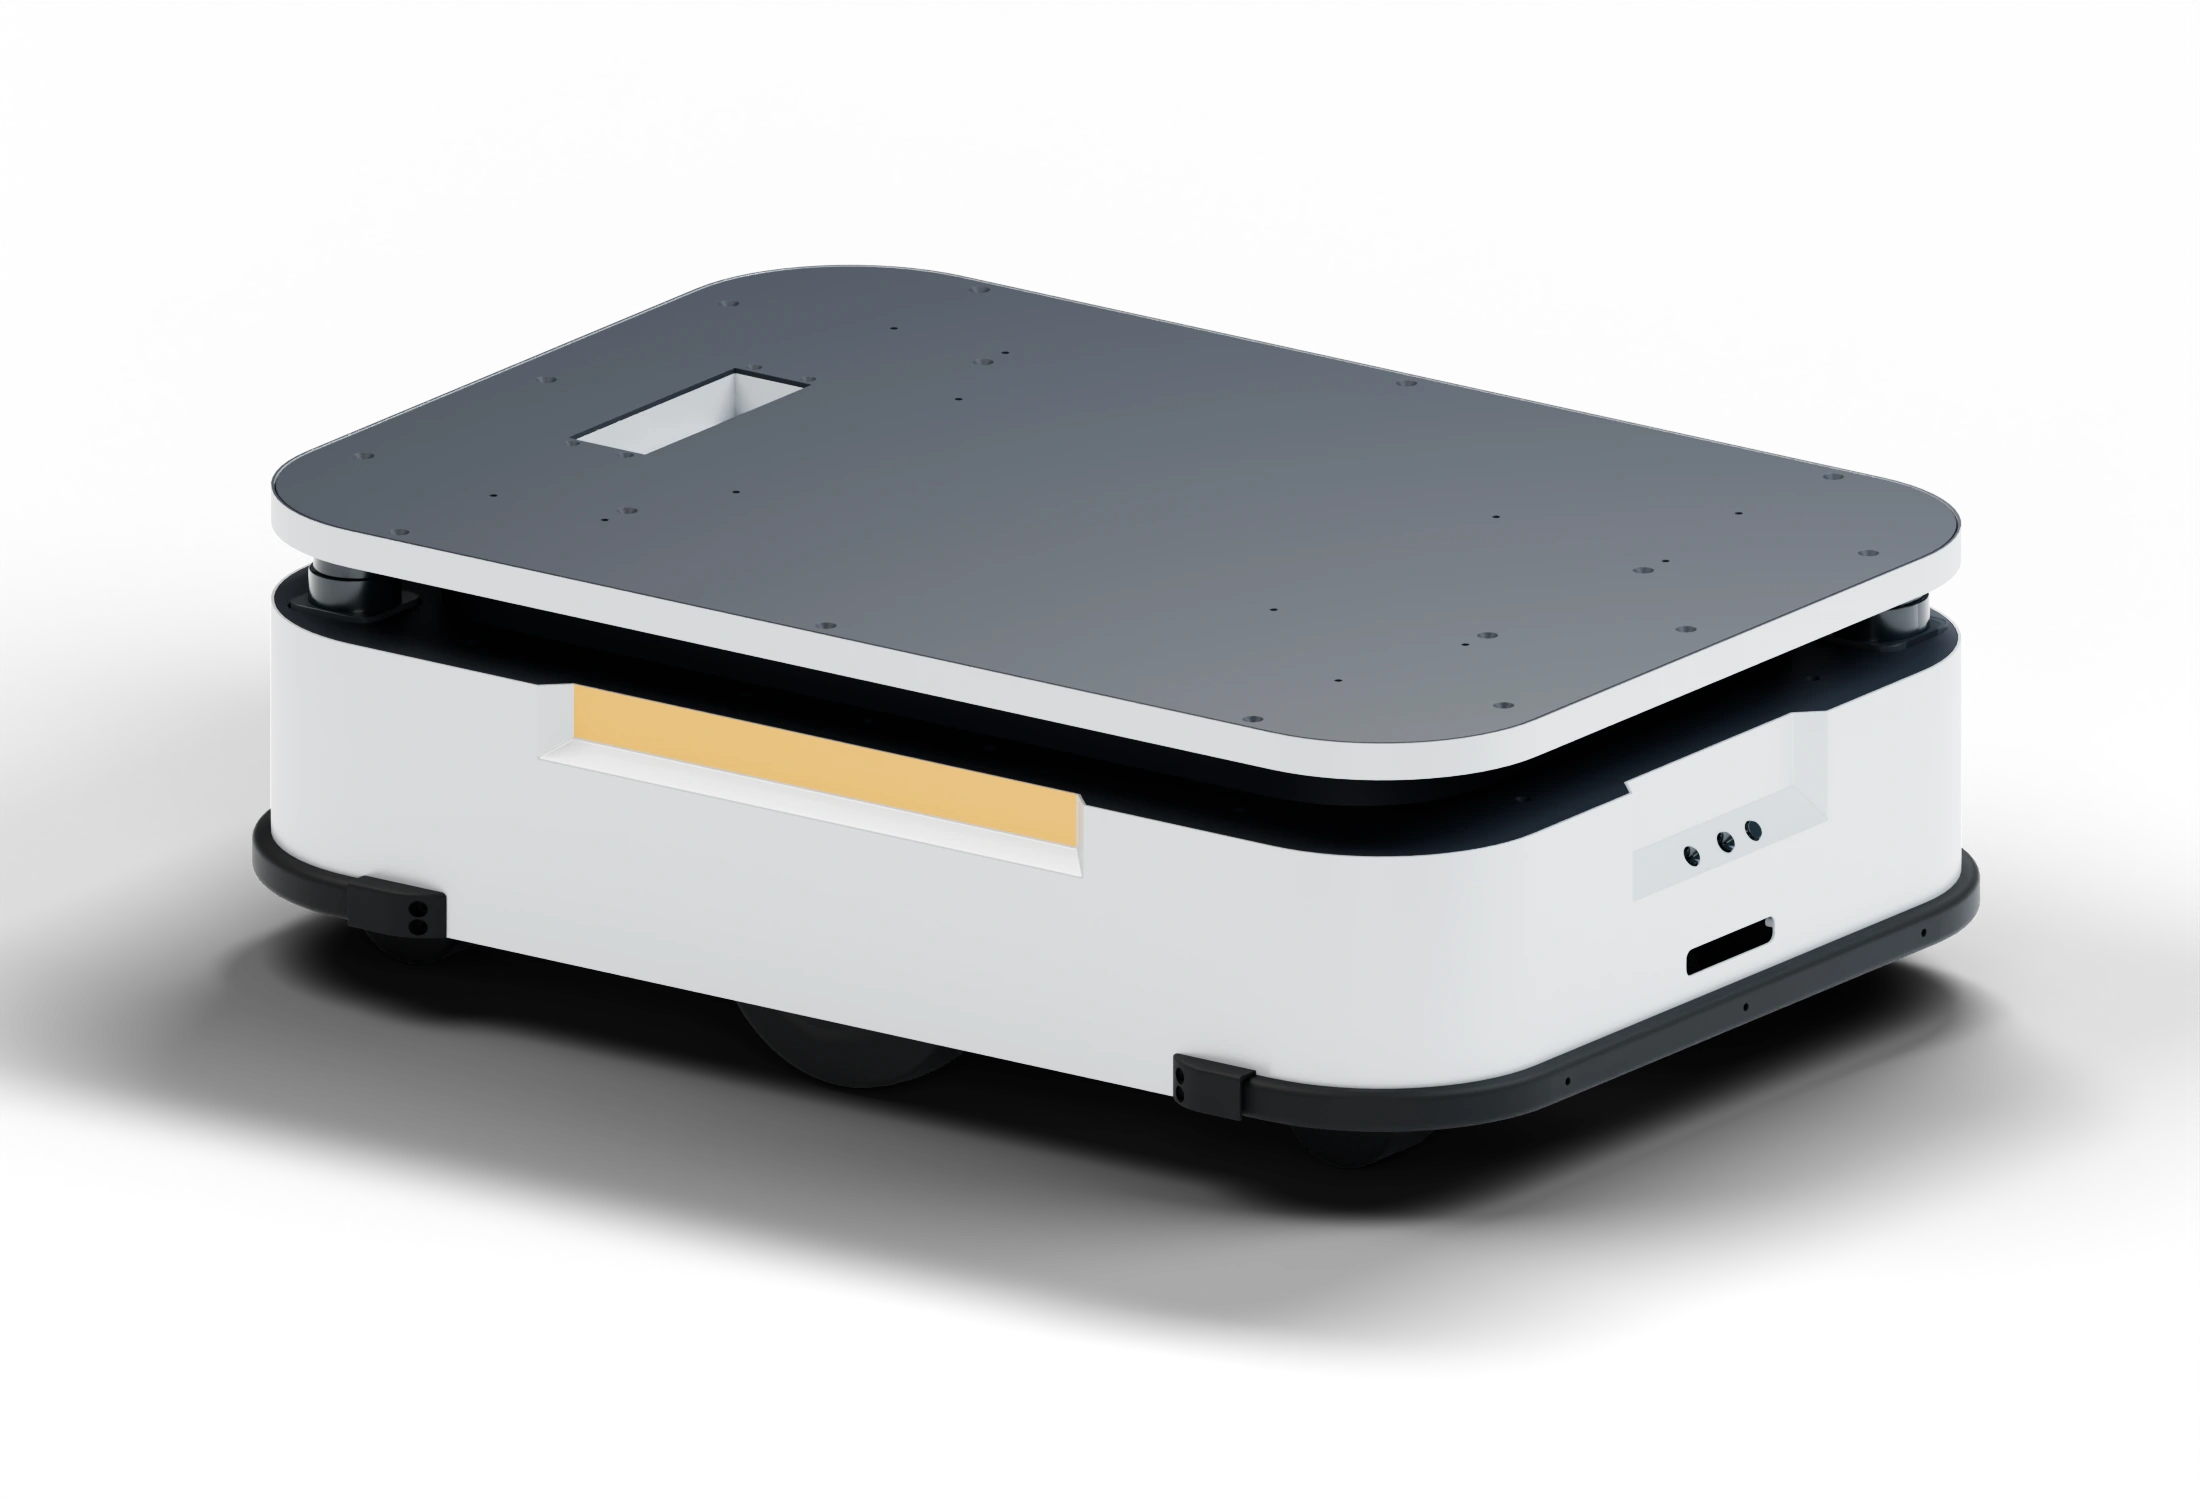
3D rendering of the FM-800 mobile robot base
FM-800 / MOBILE ROBOT BASE3D Model Rendering

MOBILE ROBOT BASES & SYSTEMS R&D

Mobile Robot Bases
& Robotics R&D

Mobile robot platforms for development and integration.
Engineering services in robotics, teleoperation and construction machinery retrofits.

FetchingRobot

Robotics · Teleoperation · System Integration

IAEIInternational Association of Embodied Intelligence
Corporate Member
01Mobile Robot BasesFM SERIES / FM-80002R&D CapabilitiesSYSTEMS / CONTROL / INTEGRATION

01 / MOBILE ROBOT BASES

Mobile Robot Bases

FetchingRobot FM SeriesFETCHING MOBILITY

FM—800
3D rendering of the FM-800 robotic mobile base
Max. Payload

150kg

Runtime (Unloaded)

15h

Max. Travel Speed

0.8m/s

FM-800 · 3D Model Rendering

MOBILE BASE / FM-800

A Platform for Robot Integration

The FM-800 brings navigation, obstacle avoidance and automatic charging together in a mobile robot base. With a payload capacity of 150 kg and power, USB and network connections, it supports equipment integration and custom application development.

LiDAR-SLAM NavigationIntegration InterfacesAutomatic Charging
Browse All Products View FM-800 Product Details
Power Output
24 V / 30 A
Peripheral Interfaces
2 × USB 2.0
Network Interface
TCP/IP
FM-800 SpecificationsShow Specifications
FetchingRobot FM-800 Mobile Base — Reference Specifications
Overall Dimensions800 × 550 × 260 mmBase Weight65 kg
Max. Payload150 kgBattery Capacity30 Ah
Runtime15 h (unloaded)Max. Travel Speed0.8 m/s
NavigationLiDAR-SLAMCharging TimeApprox. 3 h to 90%; approx. 3.5 h to full charge
Obstacle Crossing Height10 mmGap Crossing Width40 mm
Operating Temperature−10 °C to 45 °CPower Output24 V / 30 A
USB Ports2 × USB 2.0Network InterfaceTCP/IP Support
Color OptionsDark / light; custom colors available

Reference specifications are based on OEM platform documentation. The 15 h runtime is for unloaded operation; actual performance varies with payload, payload power demand and operating conditions. Specifications and appearance may vary by configuration.

WCR SERIES / RESIDENTIAL ROBOTICS

In development

WCR-160
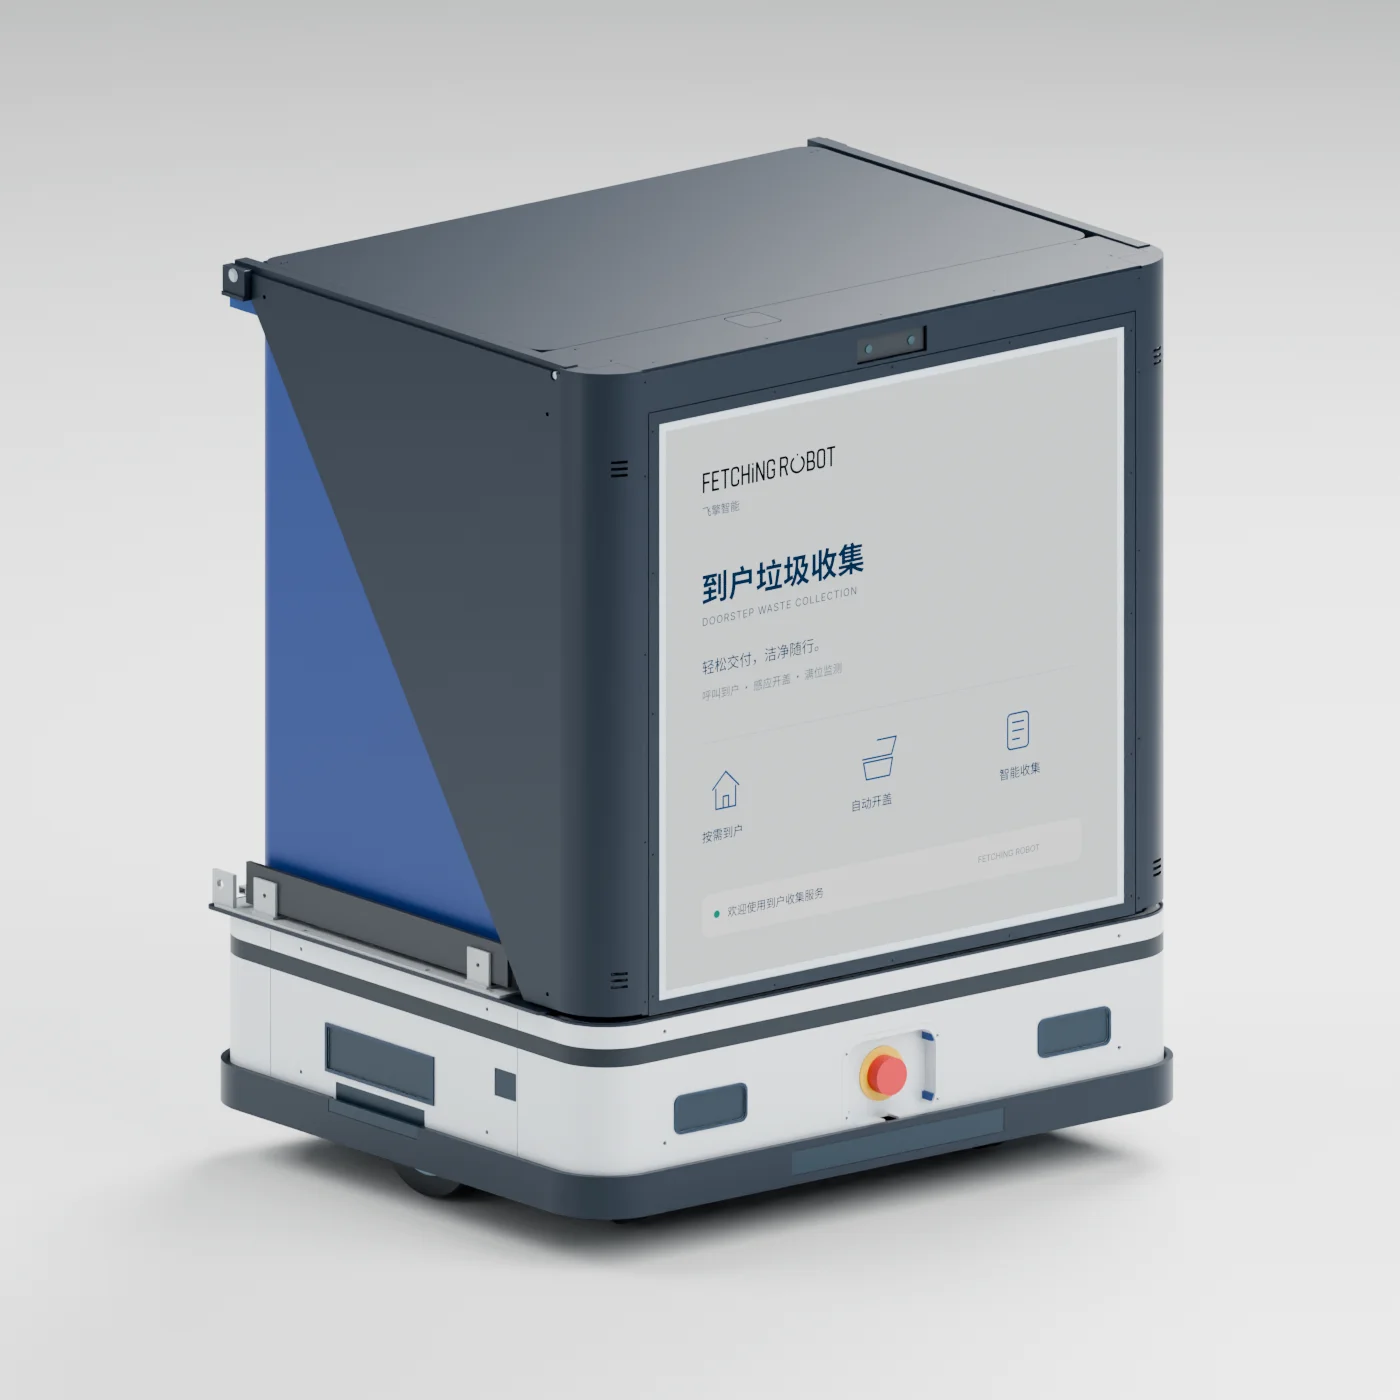
Doorstep Waste Collection Robot

Waste collection. At your door. Explore a robot designed around on-demand requests, bagged-waste loading, covered transport and staff-managed bin exchange.

Explore the WCR-160 Design
WCR-160 doorstep waste collection robot design rendering

SMART DELIVERY / SELF-SERVICE PICKUP

Product concept

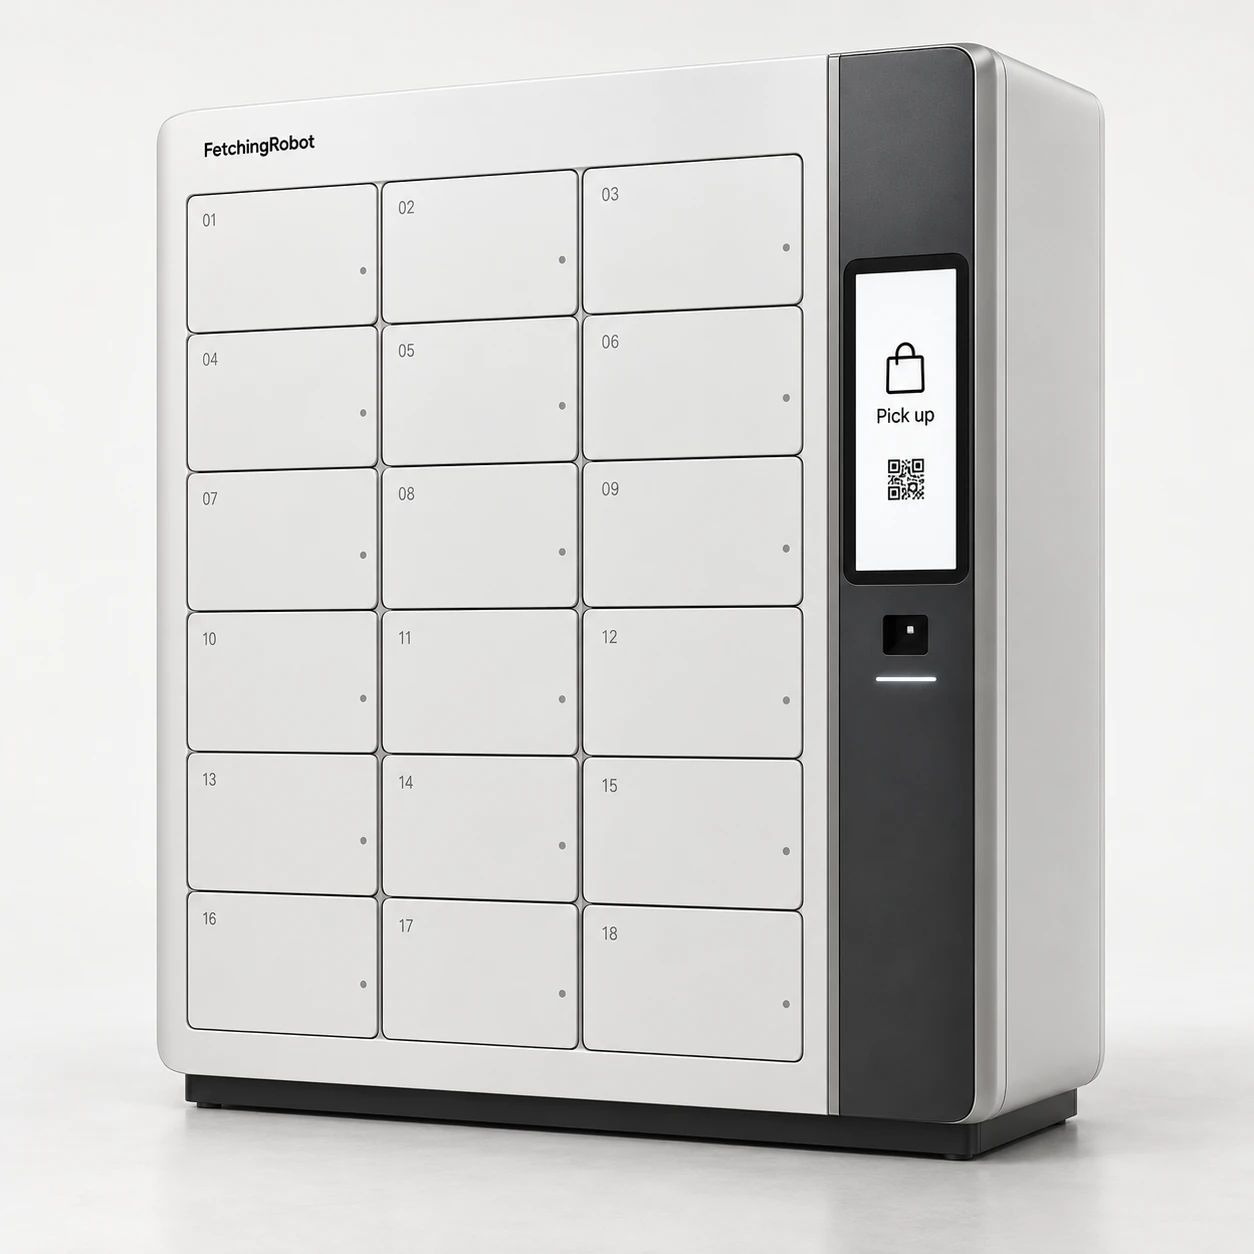
AI Smart Delivery Locker

A modular handoff concept for retail pickup, workplace item handoffs, residential deliveries and meals, with AI development focused on status sensing, exception alerts and usage analysis.

Explore smart delivery
AI smart delivery locker product visualization
Product visualization · Appearance and configuration are subject to project specifications.

02 / R&D CAPABILITIES

Robotics R&D
and System Integration

We bring mechanical platforms, control software and operator interfaces together in robot systems. Our engineering work covers system design, control development, hardware and software integration, and application testing.

01

Robotics R&D

ROBOTICS SYSTEMS

Our robotics development combines mobile platforms, actuators, sensors and control software. We design system architectures and integrate components around the movements, payloads and operating sequences required by the application.

System Design
Architecture and component selection for mobile platforms, actuators and sensors.
Control Development
Motion commands, machine state management and task sequencing.
Application Integration
Payload integration, device interfaces and application testing.
Explore Our Engineering Approach
02

Robot Teleoperation

ROBOT TELEOPERATION

We develop the controls and feedback that allow an operator to work through a robot from a remote location. This includes translating operator inputs into robot actions, connecting to the robot’s control system, and presenting status and visual feedback.

Operator Interaction
Mapping operator inputs to equipment actions.
Commands & Feedback
Command transmission, robot status and feedback from the work area.
System Integration
Robot control interfaces, operator stations and communications.
Explore Teleoperation R&D
03

Construction Machinery Retrofits

MACHINERY RETROFITS

We develop remote-control, monitoring and operator-assistance functions for existing construction machinery. The engineering work connects new controls and feedback to the machine’s existing actuators, signals and control systems.

Control Integration
Integration of remote commands with existing machine controls.
Status Monitoring
Machine status, motion feedback and information from the work area.
Operator Assistance
Task-specific prompts, control functions and operator interfaces.
Explore Machinery Retrofits

03 / TELEOPERATION & RETROFIT

Teleoperation & Monitoring
for Construction Machinery

FetchingRobot develops the interfaces between remote operators and construction machinery. Our work covers machine control, communications and feedback, with operator interfaces designed around the task and the equipment.

OPERATOR

Operator Station

Operator input · Command mapping

CommandsStatus Feedback
CONNECTION

Communication Link

Control commands · Status data

Control IntegrationSite Information
MACHINE

Machine

Actuator control · Machine status

Illustrative Teleoperation System Architecture

MACHINE CONTROL

Remote Control Integration

We integrate remote commands with existing machine controls and actuators. Control development covers input mapping, local and remote operating modes, and the handling of communication loss and interrupted commands.

  • Machine interfaces and actuator controls
  • Command mapping, mode switching and exception handling

Control Integration · Action Mapping · Mode Switching

ENGINEERING APPROACH

From System Architecture
to Application Validation

Our engineering work spans system design, control software, integration and testing. Each discipline addresses a different part of the complete system, from mechanical and electrical interfaces to software behavior under operating conditions.

  1. 01

    System Architecture

    Defining how the mobile platform, actuators, sensors and controllers work together, including component selection and mechanical, electrical and data interfaces.

    Technical Focus

    Platform Configuration · Module Coordination · Interfaces

  2. 02

    Control Software

    Developing motion commands, machine states and task sequences, including feedback handling and responses to faults or interrupted communication.

    Technical Focus

    Motion Commands · State Management · Task Logic

  3. 03

    Hardware–Software Integration

    Integrating devices, electrical connections and communication links with control software and application functions.

    Technical Focus

    Electrical Connections · Communications · Software Interfaces

  4. 04

    Engineering Validation

    Testing control response, feedback, task sequences and fault handling across the loads and operating conditions relevant to the application.

    Technical Focus

    Functional Tests · System Interaction · Operating Conditions

04 / ABOUT FetchingRobot

FetchingRobot

FetchingRobot supplies mobile robot bases and provides engineering services for robotics, teleoperation and construction machinery retrofits. Alongside the FM Series platforms, our work includes control software, equipment interfaces and application development, bringing hardware and software together for industrial tasks.

Brand
FetchingRobot
Engineering Focus
Robot control and system integration
R&D and Services
Robotics systems, teleoperation and machinery retrofits
Product Platform
FetchingRobot FM Series · FM-800 Mobile Base
RESEARCH FOUNDATION

R&D Background

Our robotics and teleoperation development draws on technologies originating from Tsinghua University and Beihang University, with an emphasis on their application to working robot systems.

Tsinghua UniversityBeihang University
INDUSTRY EXCHANGE

IAEI Corporate Member

IAEI+

FetchingRobot is a corporate member of the International Association of Embodied Intelligence (IAEI). IAEI promotes international exchange in embodied intelligence, robotics, artificial intelligence, perception and human–machine interaction.

About IAEI
ROBOTICS. CONTROL. INTELLIGENCE.FetchingRobot
Monochrome FetchingRobot wordmark

Robotics Engineering · Teleoperation · Machinery Retrofits

Back to Top